Page A perspective, not a yespage three.
Recording hand-eye coordination, masking relationships and Actions intent is better suited to learning to capture and finely assemble than static surveillance Camera。
R99M Ego Vision Egocentric · Page A perspective
Learning for Personal Intelligents and Emulations: Multiple Model Data with a Page Perspective SyncForging RGB, Depth, IMU, Power and Audio, fully customized, hardware and software to capture, assemble and implement strategies。
- We have an account? ego.lookzn.com Use Web Foruming and Quality Checking Platform
What is Ego Vision
Egocentric Vision(♪ Medium Heart Visual ♪)—— From the perspective of the world, where Author or the robotic body Page is one person, Yes has the core input of a smart data wheel.。
Recording hand-eye coordination, masking relationships and Actions intent is better suited to learning to capture and finely assemble than static surveillance Camera。
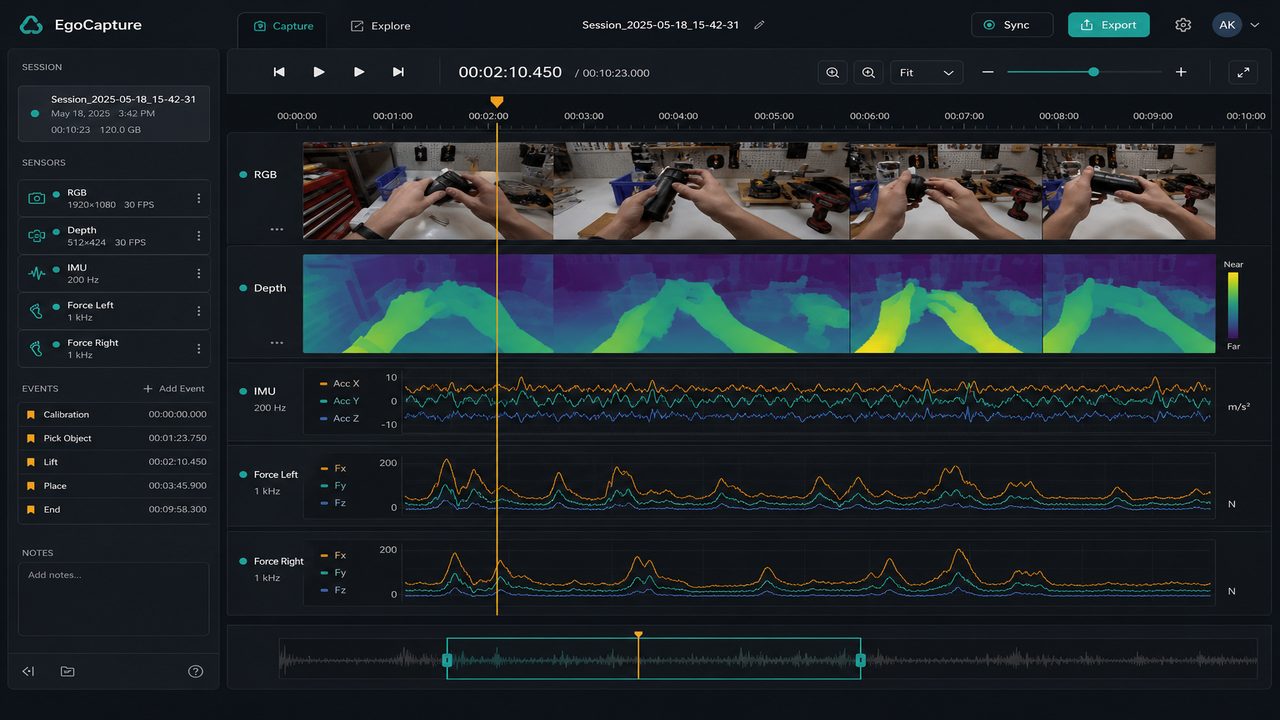
VideoAlign with depth, IMU, joint angle, strength/tactile, audio at the same time axis, reducing later-stage cleaning costs。
Output LeRobot / HDF5 / MCAP format, docking VLA, Diffusion Policy with Remote Actions。
From head-dressing/ wrists/breathing for Forage hardware to recording, labelling, Export software, custom-made for laboratory or production-line settings。
Hardware
Modular POV Foraging hardware to support monotone and multi-person Collaborates production lines。
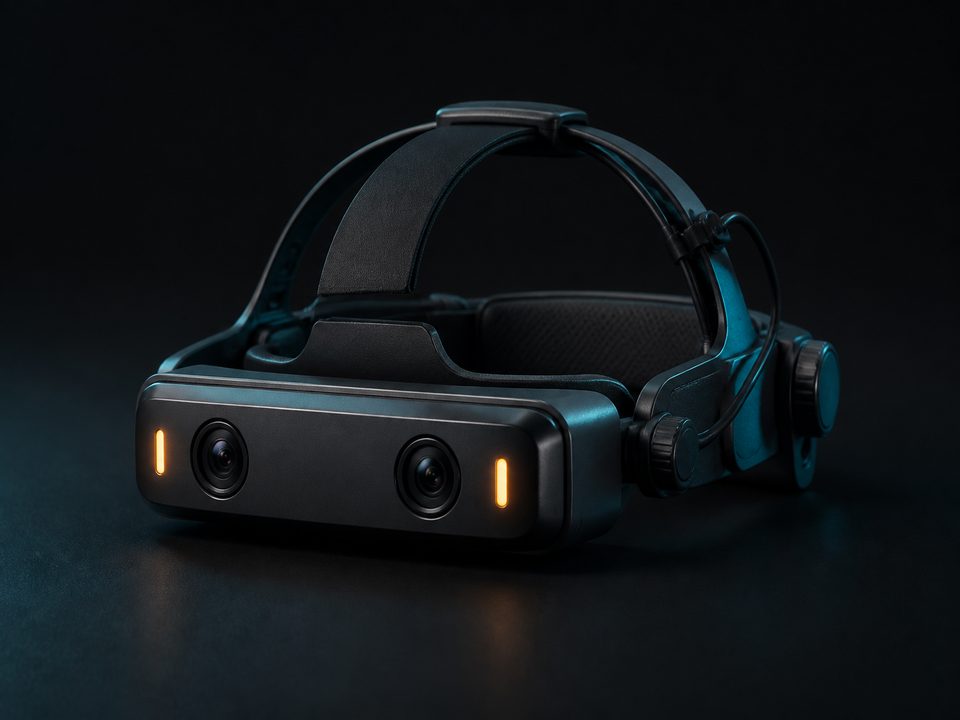
Headwear. · Main Perspective
Double / RGB-D · 1080p@60 · LowDelay
View camera close to the human eye axis, Office IMU and ToF depth, suitable for desktop actions and laboratory instruction。
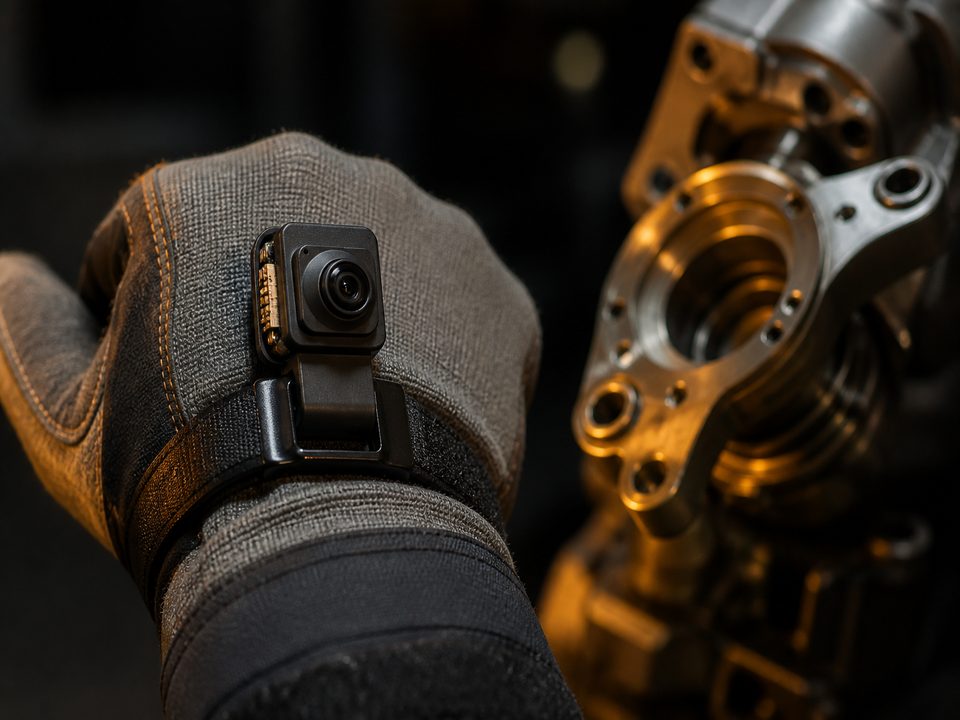
The wrist. · Hands.
Mini MIPI · Waterproof oil · Take it down.
Catch details of the grab and tool use, complement the main view, and lower the Low cover blind area。
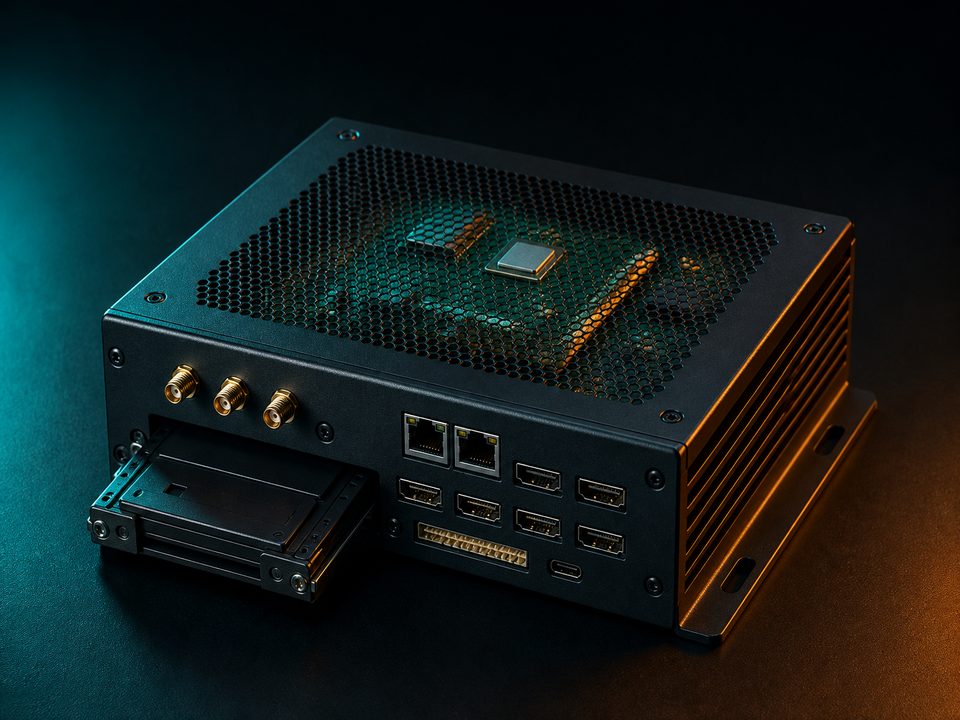
PeripheralHost
RK3588 / RK3576 · Multi-way. MIPI · SSD
Gather 4–8 Path POV and Sensitivity Data, Local CodeStore, backup for Gige / WiFi6。
List of hardware specificationsSoftware
SyncEngine
RGB / Depth / IMU / PowerSense and Preview, one key to start, event tag, quality alarms and training formatExport。
Multiple Path Preview, one key opening, event tag, disk health management; support for remote parameters and OTA。
Snippets, Access/FailedTags, Blur Frame Tests, Less dirty data into the training set。
HDF5、LeRobot Dataset、Customized JSON; docking PyTorch/ JAX tubes。
The Sync engine and burner tool can be authorized separately for self-research hardware on the first side and settled by table。
Cases & Demo
Below is the typical Demo cover; complete prototype Video can use Passed micro-letter reservation remoteDemo。
Headwear. POV + The wrist camera Sync records, Export to imitate the learning pipe. ClickBook a DemoVideo。
Skilled workers wear the Foraging package, mass build assembly strategy data sets. ClickBook a DemoVideo。
Page One view Low delays Link, Service remote manipulation and visual-Language-action models. ClickBook a Demo。
Standard Kit
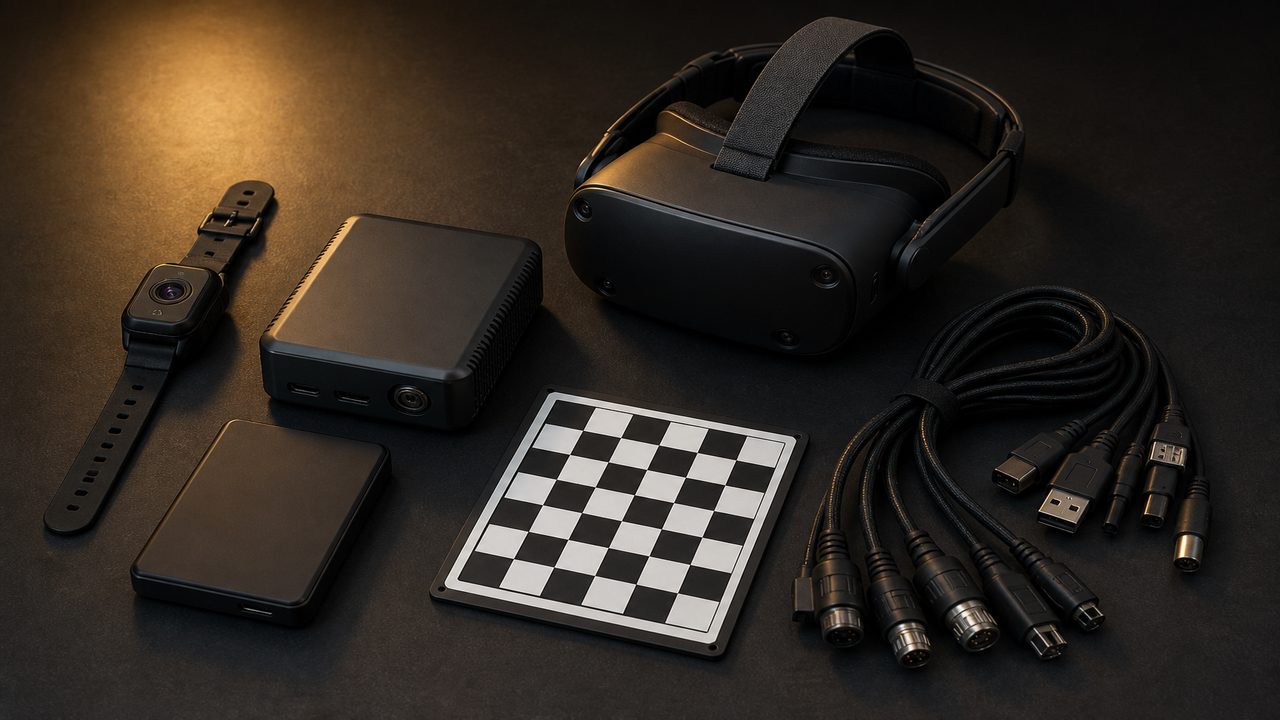
Head with main view, wrist camera, Peripheral mainframe, SSD with placards,2–4 ♪ The week can shine ♪Demo。
Platform
Multi-Trouble 1080p Code + NPU,Fits for PeripheralForageing Host with onboard pre-processing。
desktop capture depth monitoring;tight alignment with RGB。
Head/ wrist posture and tool trajectory, auxiliary action segment。
Plug, press pressure, assemble curve into the library.。
Scenes
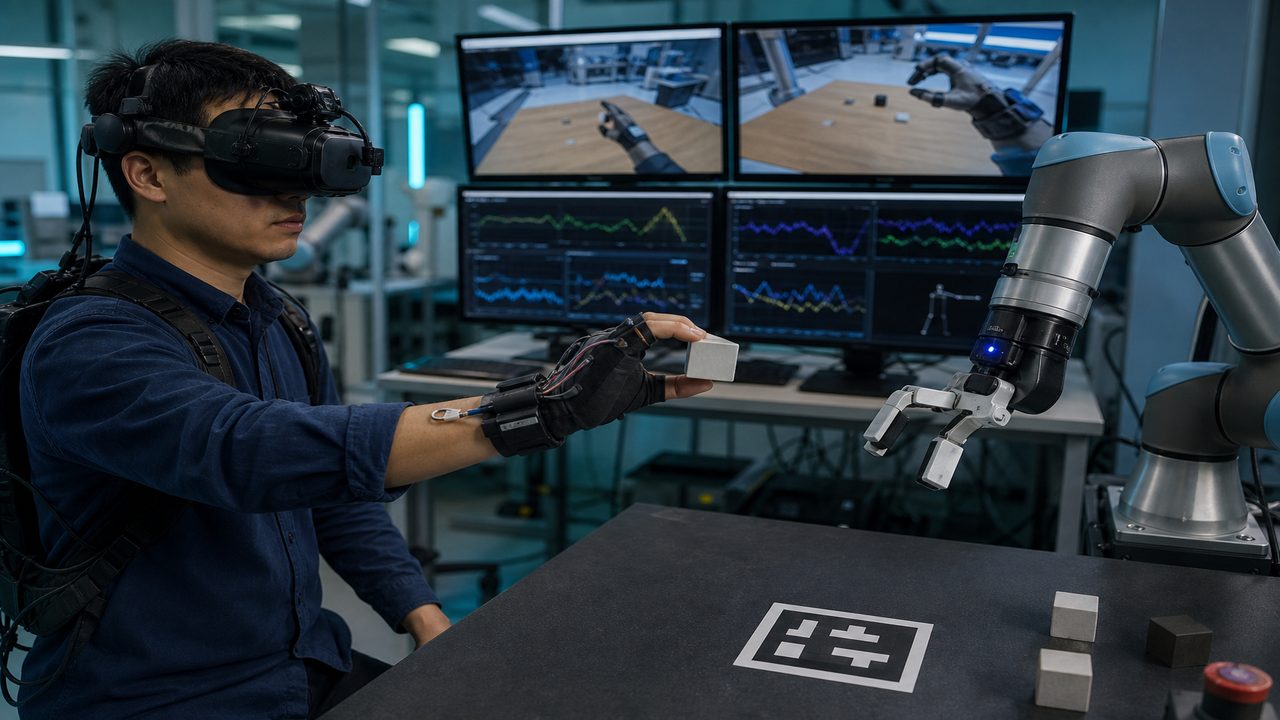
Ego Davis, researcher, teaches, quickly builds up capture and place data sets。
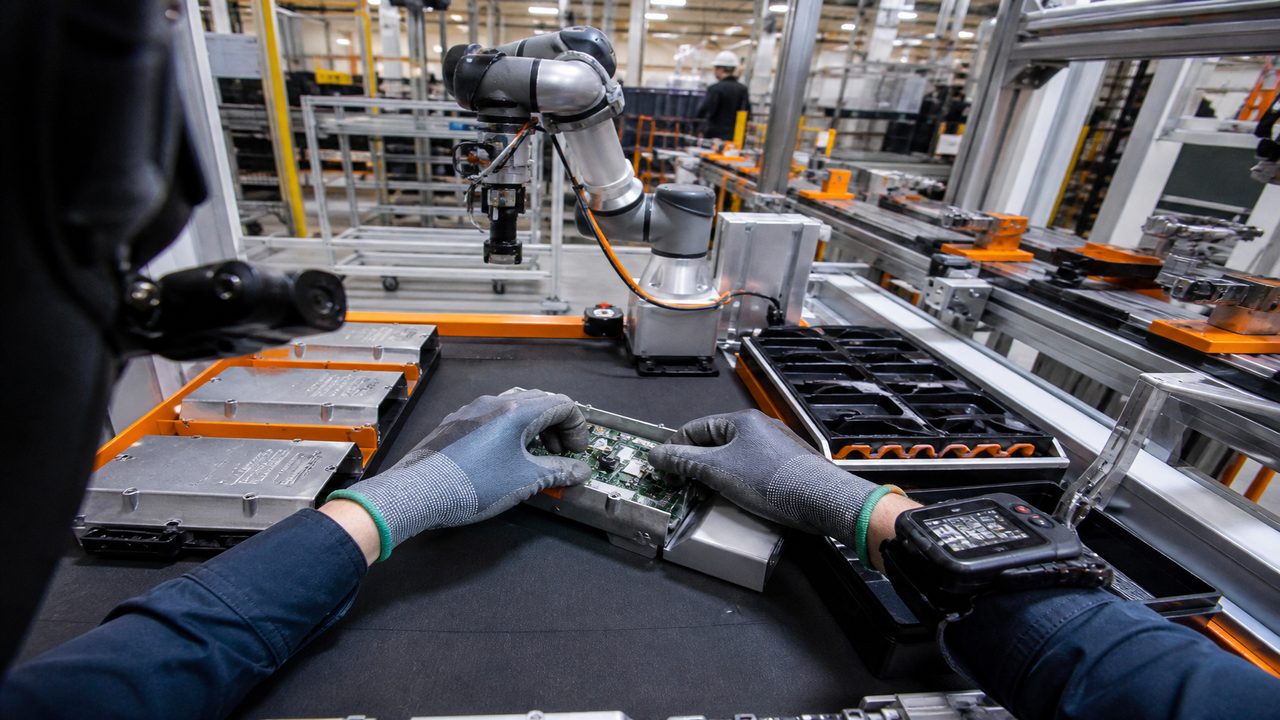
ForagingSkilled workers Actions, Microation to Collaborates robotic or quality-check models。
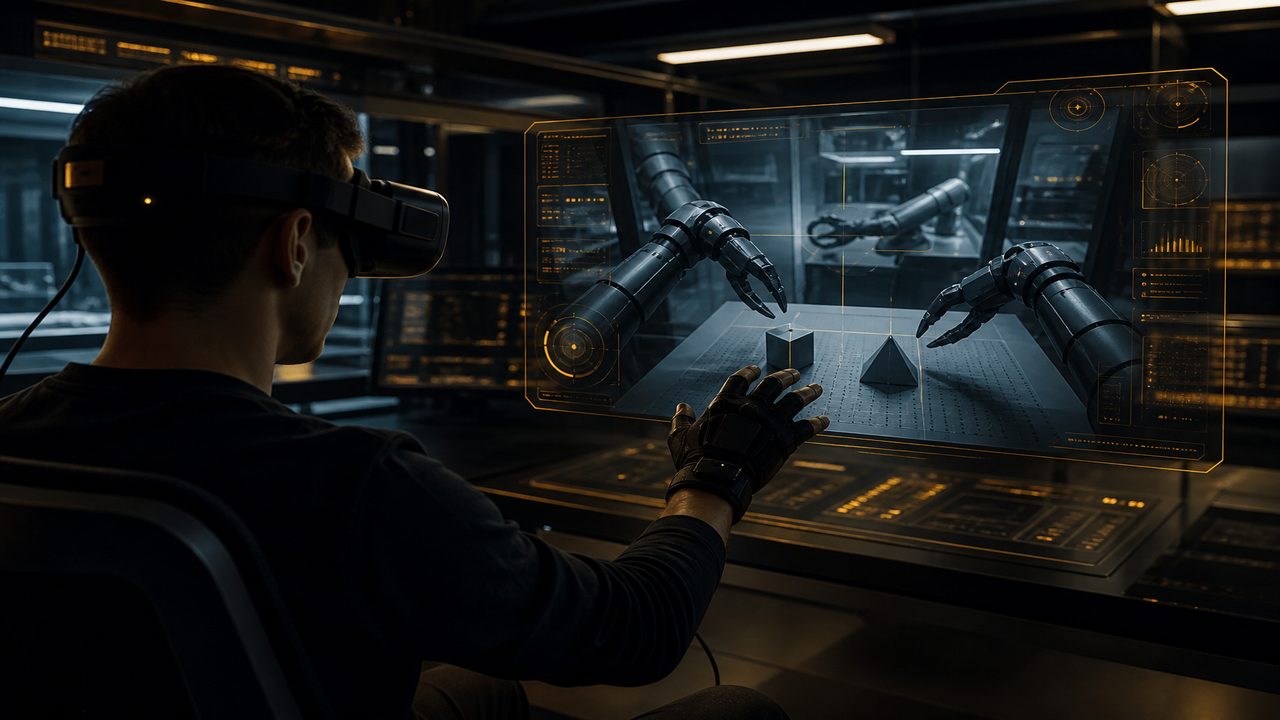
Page A perspective + LowDelay Link, Servicees remote manipulation and visual-Language-action models。
Contact
Provide Solution Assessment, Samples andMass Production and Delivery · Phone/We can not open message 18616597379
Scan or search the WeChat ID to add
WeChat ID:18616597379